From handsto humanoids.
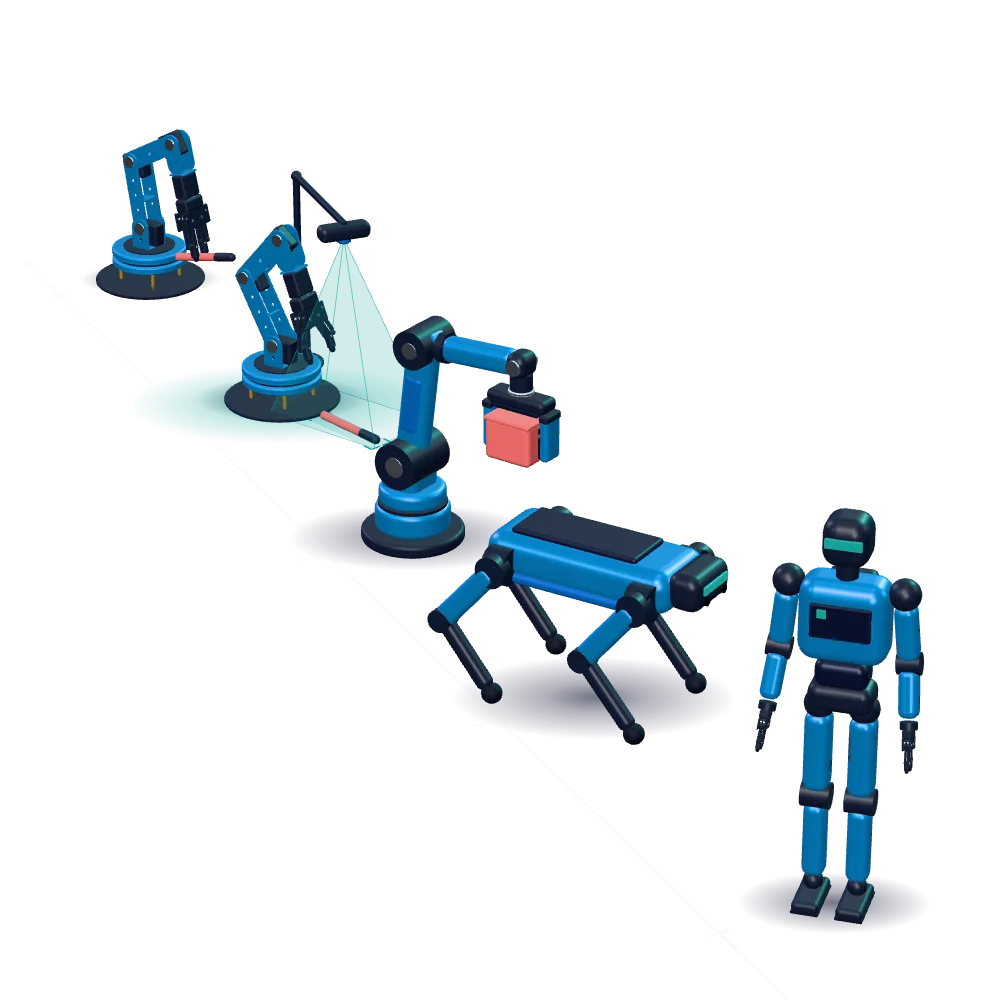
Each step uses what we learned in the step before.
Five steps. Each one adds a skill.
- 01
Hands
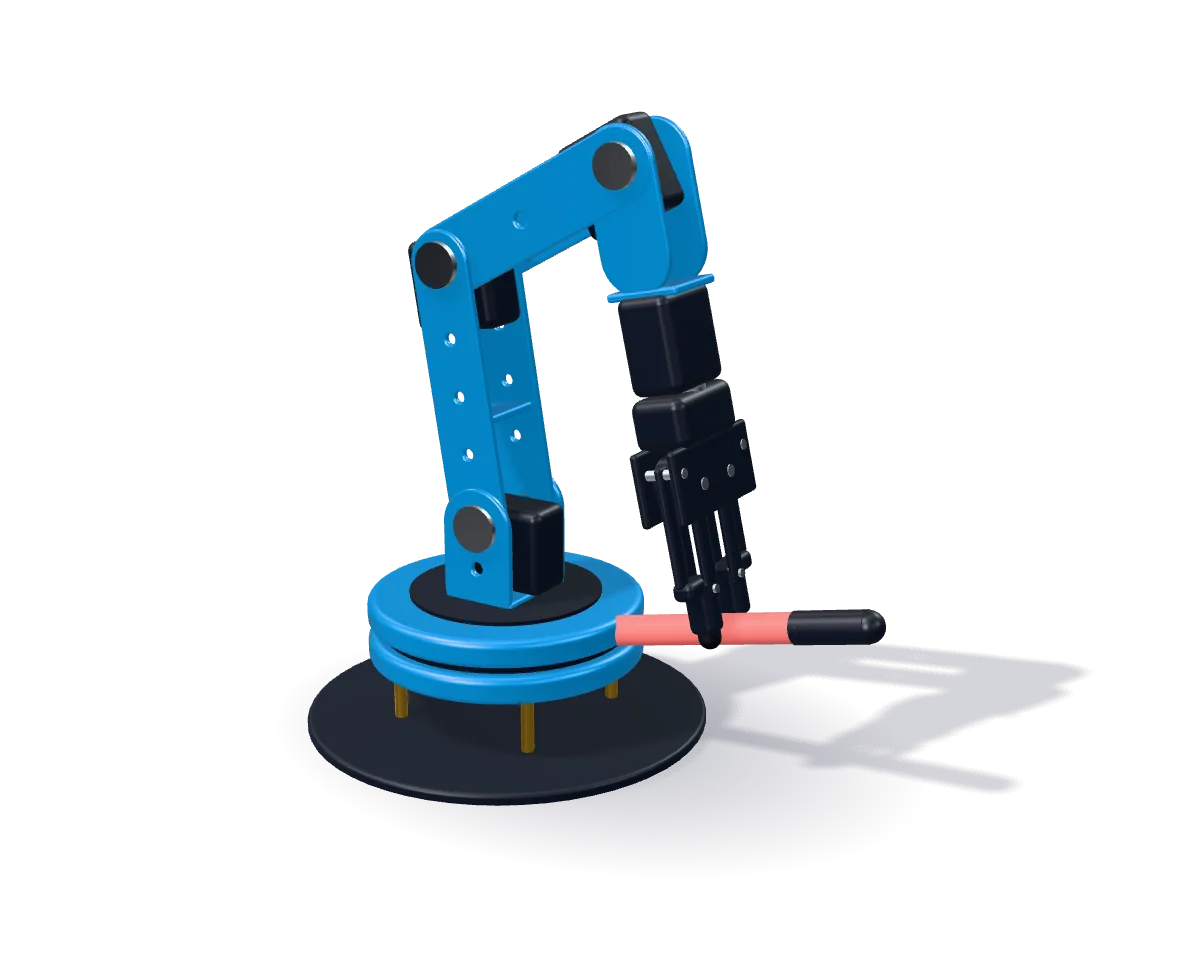
A desk arm with two fingers. It learns to reach, grip and place.
- 02
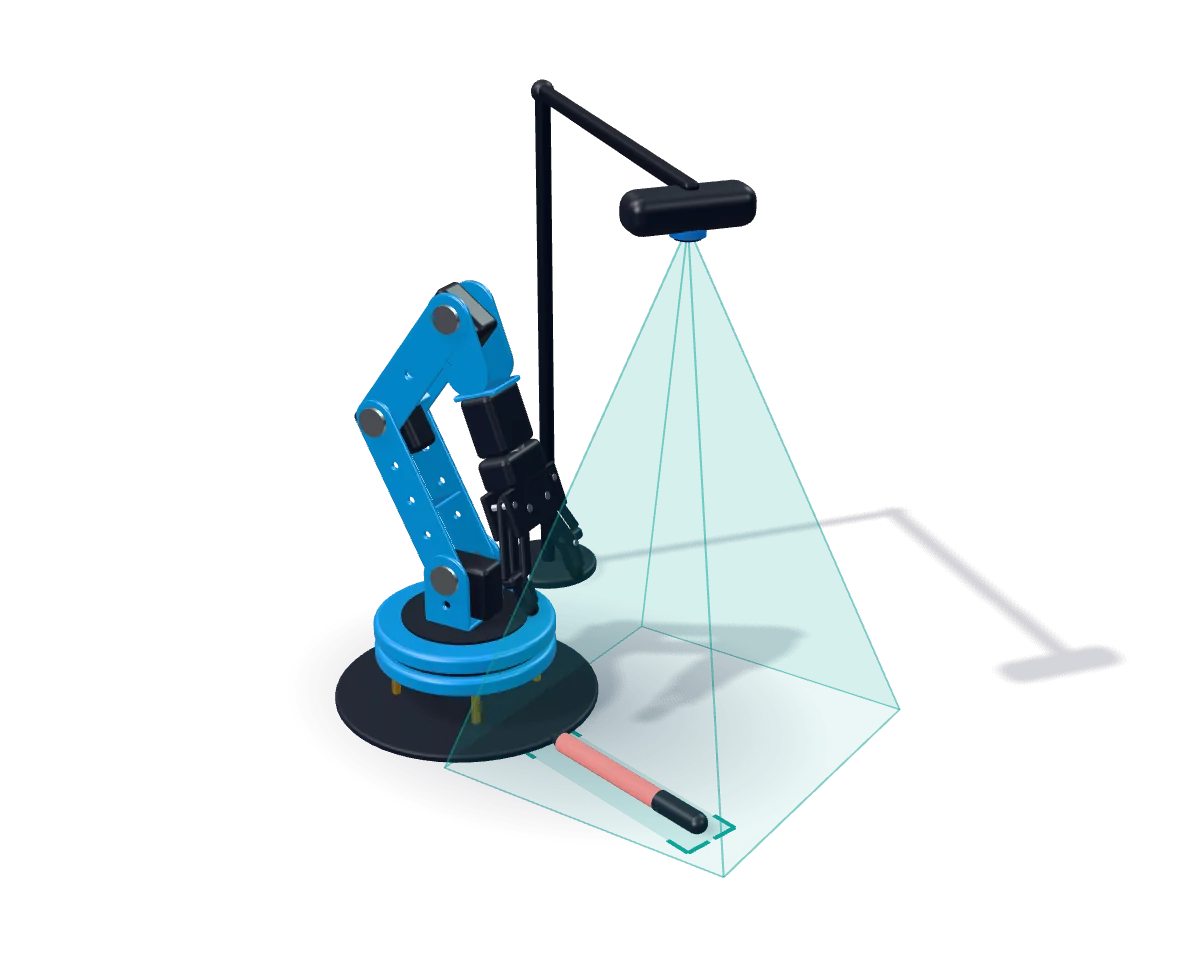
Hands + vision
NowA camera looks down at the table and guides the hand.
- 03
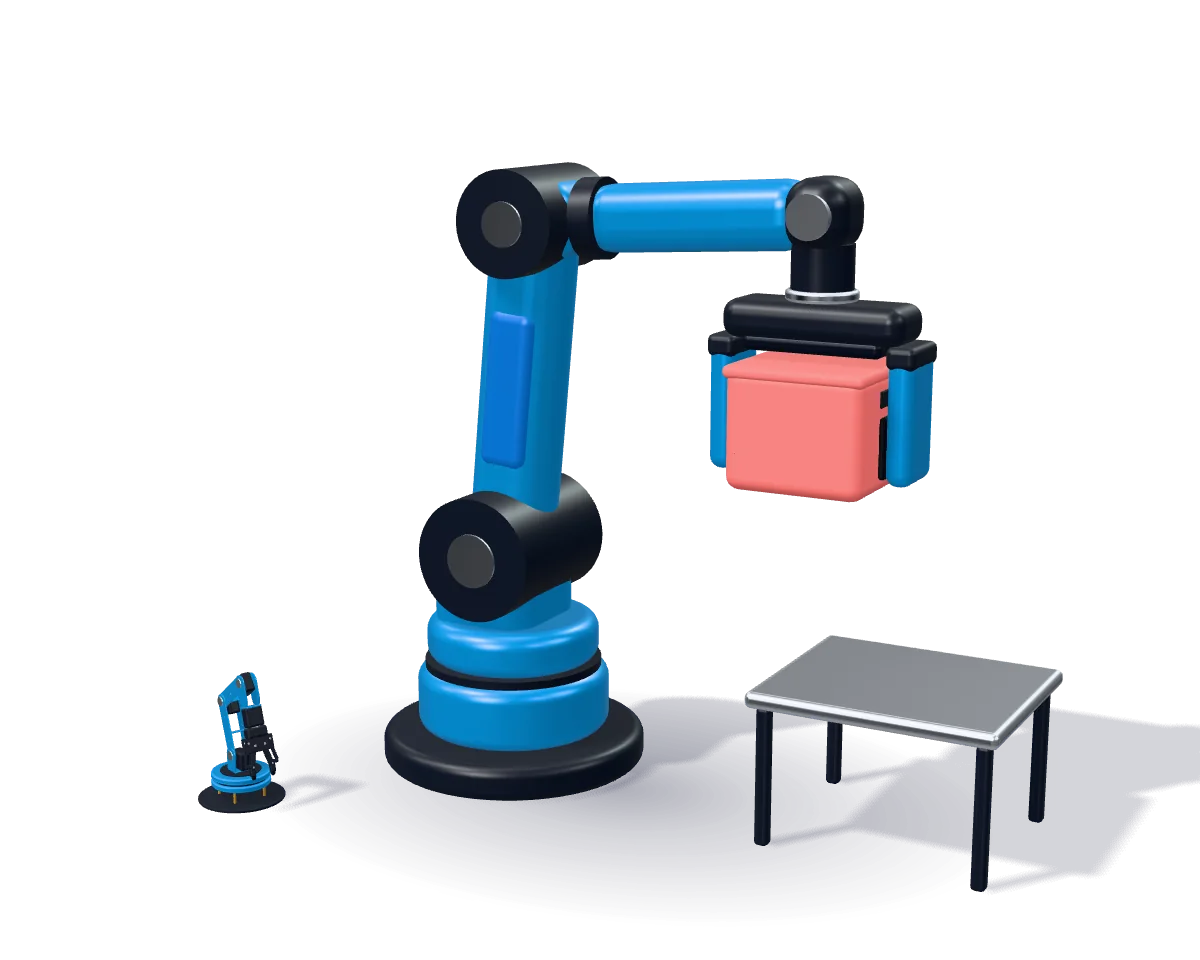
Bigger hands
Stronger arms that lift more and reach further.
- 04
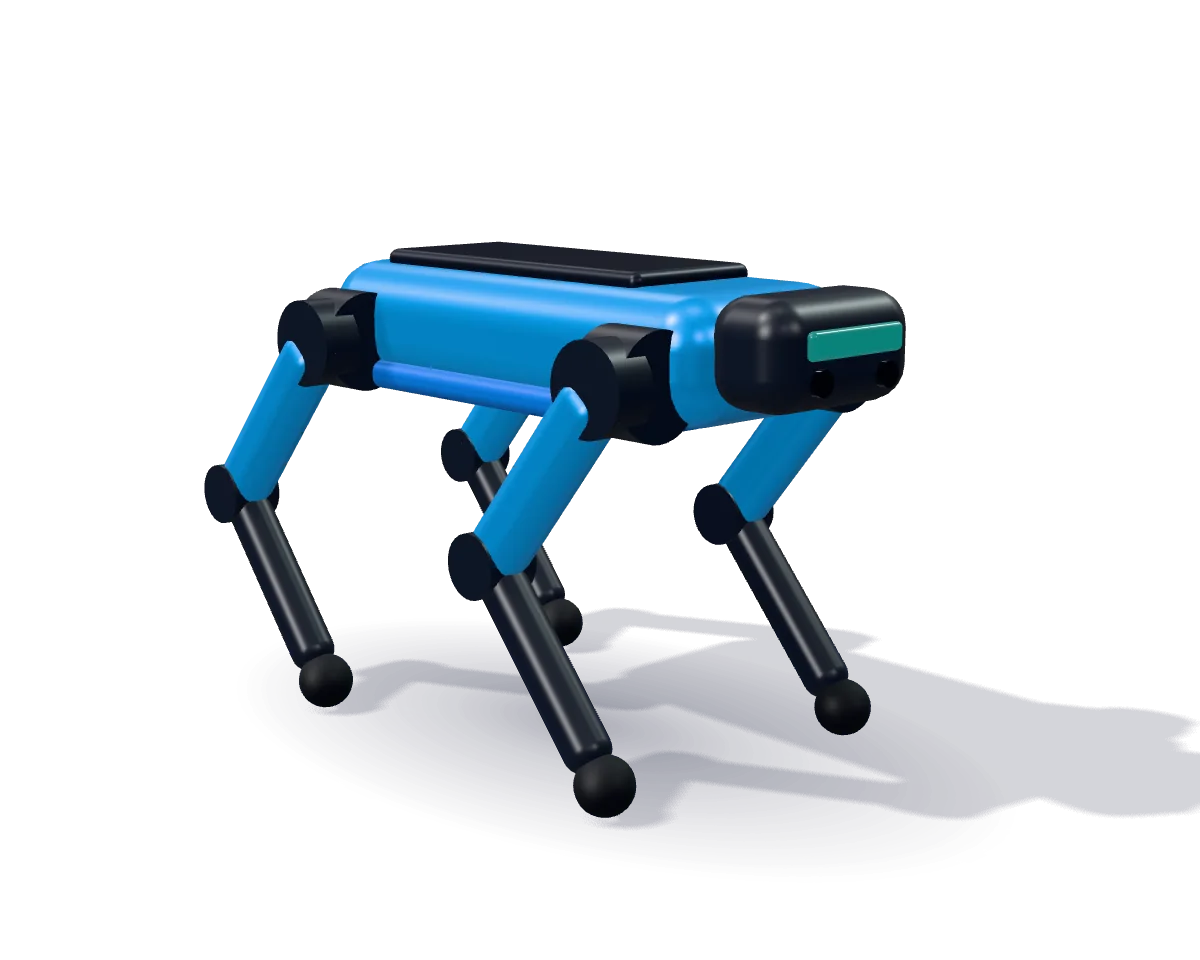
Four legs
A robot that walks on four legs.
- 05
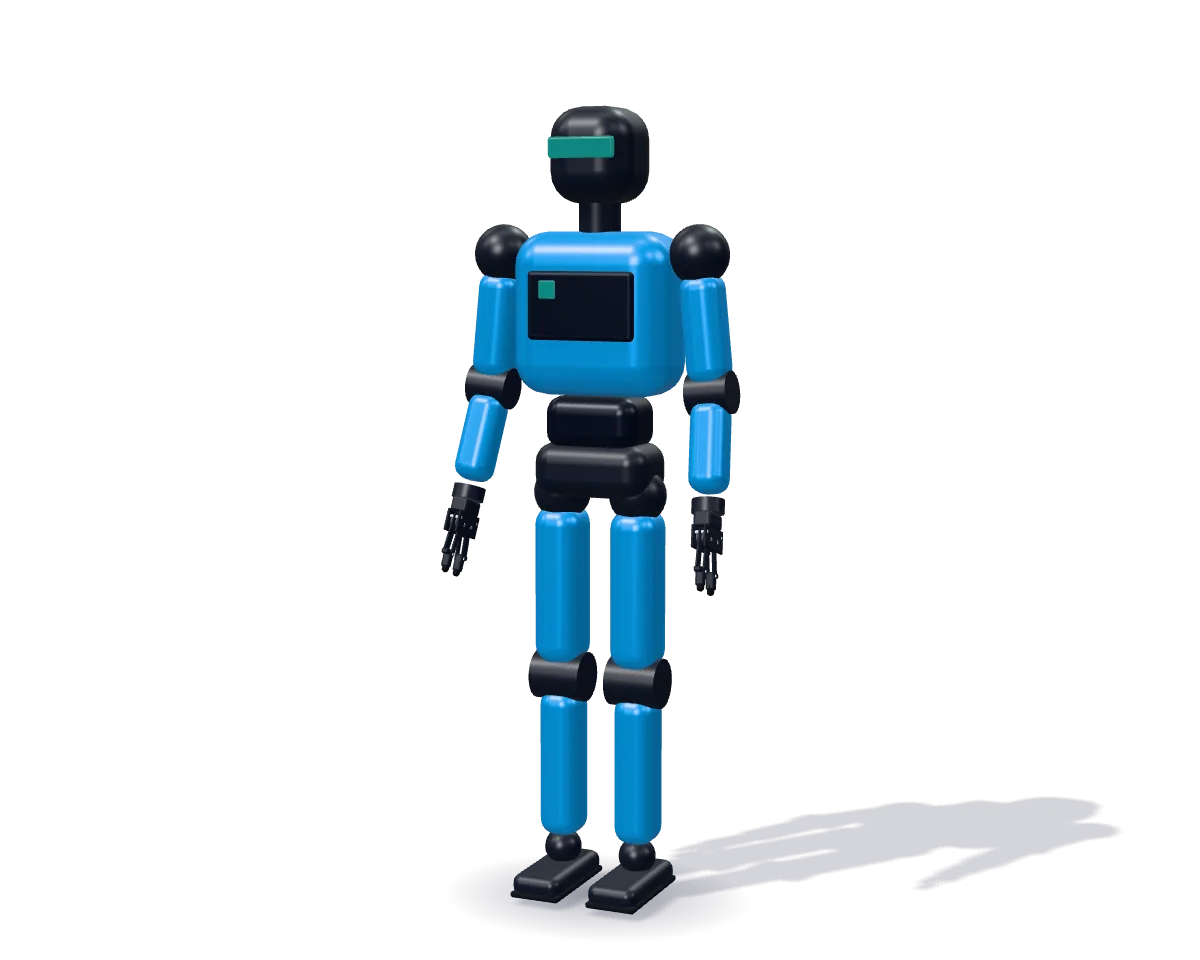
Two legs · Humanoid
A humanoid robot that walks and works with its hands.
Two phases. Learn first. Then build products.
R&D
Now2026–2027
We build and test each skill in our lab. The journal shows the work.
Products
Actuators first2028–2029
The motors and gears that move a robot's joints.
See products
See the work. From our lab.
Our journal shows each day in the lab: what we tried, what worked, and what we learned.