R&D journal

Code meets the real world.

After each day in the lab, we write down what we did and what we learned. The photos and videos are real.

Latest day: RSS feed

Week of Nov 2 – 8, 2026

The eye learns to handle the real, messy view

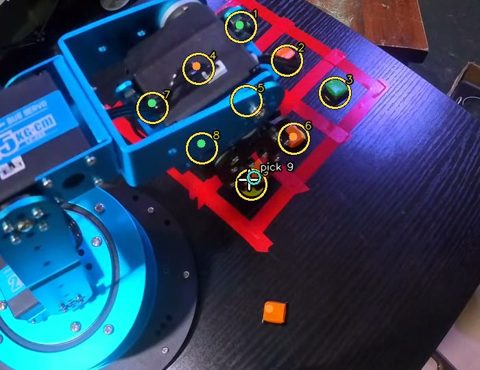
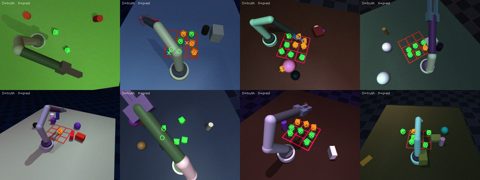
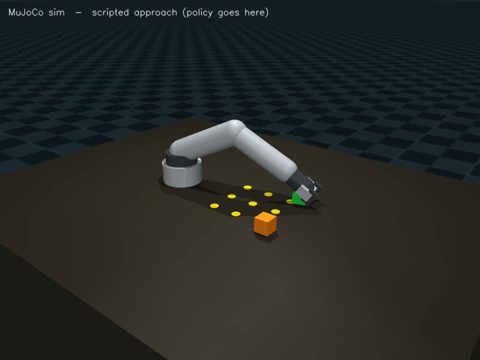
The robot's 'eye' had only ever practised on tidy simulated pictures, so we rebuilt the practice world to be harder than real life — an angled, roving camera, several cubes at once, and random clutter to ignore — and retrained it overnight on our own PC. It now reads the real camera's full picture, with nothing cropped out, finds every cube and steps over almost all the clutter.
1 day

Week of Oct 26 – Nov 1, 2026

A website, and the move into simulation

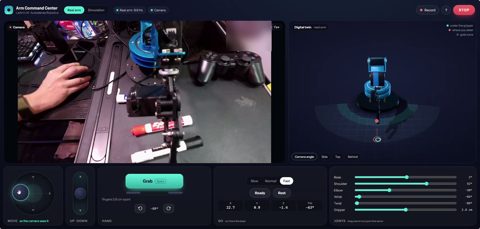
We put robotics.autosterea.com online — built from this journal — and cleared the first cubes with the real arm. Then we gave the arm a twin inside a physics simulator and used it to train the robot's first 'eye': a small model, taught entirely on practice images the simulator labelled itself, that now finds the cubes in a picture to within a few pixels.

3 days

Week of Oct 19 – 25, 2026

The arm arrives and picks up a pen

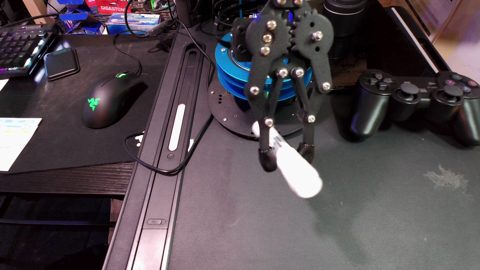
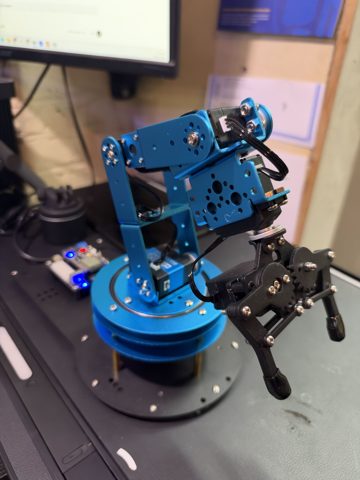
The Hiwonder LeArm AI arrived on Saturday, and by evening it was taking commands from our code over USB, with safety checks so a bad reading can never turn into a wild move. On Sunday it picked up a marker, spun it, drew a circle in the air and put it back, in a 23-second routine it runs by itself.

2 days

Week of Oct 12 – 18, 2026

Day one: a camera that reads a phone

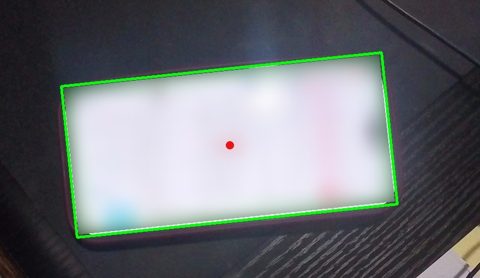
We started with the camera. It streams into our Python code, finds a phone lying on the desk and straightens its screen so small text can be read. The arm was still on its way.

1 day